About us
Aquatonomy is a marine robotics and data intelligence company helping organizations see, measure, and monitor critical underwater assets. We combine autonomous robotic systems with 3D mapping and AI-assisted analysis to improve inspection, maintenance, and long-term asset decisions.
Our story
Aquatonomy grew out of more than 17 years of research in perception, localization, navigation, and mapping at Carnegie Mellon University, MIT, and the University of Michigan. Related technologies have supported autonomous systems operating on the International Space Station, lunar rovers, aircraft, land vehicles, vessels, and underwater robots.
We founded Aquatonomy to bring these capabilities to one of the world's most challenging and consequential environments: the underwater infrastructure and critical assets that support energy, transportation, trade, defense, and public safety.
Today, Aquatonomy is building on this research foundation to deliver a commercial platform for comprehensive underwater data collection, measurement-grade digital twins, repeatable inspections, and long-term condition intelligence.
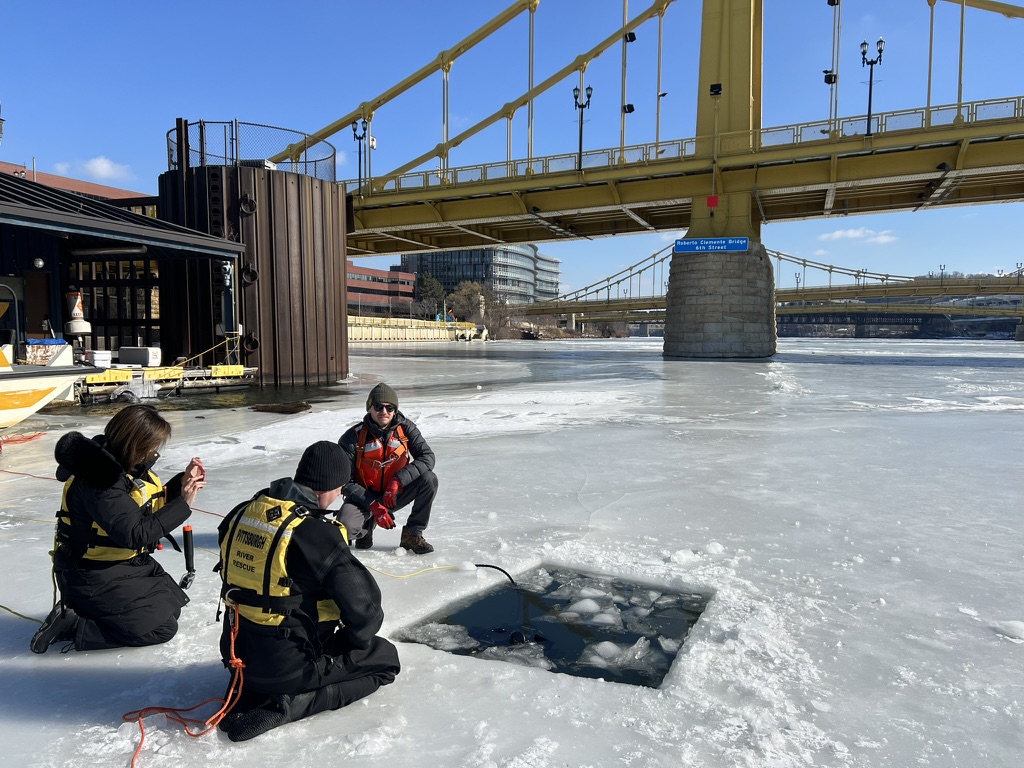
Our mission
Better underwater information can reduce risk, avoid unnecessary disruption, support earlier intervention, extend asset life, and help organizations make more confident maintenance and capital decisions.
Why now?
Aging infrastructure, growing maritime activity, extreme weather, and limited inspection capacity are increasing the cost of managing submerged assets with incomplete information. At the same time, advances in autonomous robotics, sensing, and 3D data systems make comprehensive, repeatable underwater inspection possible at a new scale.
Aquatonomy is building the connection between these two worlds: robots that reliably collect data and a digital platform that turns the data into long-term asset intelligence.
Our founders
Leadership across autonomy, product development, and commercialization.
CEO and Co-founder
Michael is a leading expert in robotic perception, navigation, localization, and mapping. His research has advanced autonomous systems operating in space, on land, in the air, at sea, and underwater. He leads Aquatonomy's technology strategy and the development of high-performance autonomy for complex inspection environments.
COO and Co-founder
Xiaoyu brings more than 16 years of experience bringing B2B technology to market, with deep expertise in the architecture, engineering, and construction (AEC) industry from her product leadership at Autodesk, as well as experience at Oracle and GE Healthcare in collaboration with UPMC. At Aquatonomy, she leads business strategy, customer development, operations, and go-to-market execution, bridging advanced robotics and AI with real-world industry needs. A certified diver, Xiaoyu also brings firsthand understanding of the challenging underwater environments Aquatonomy is working to disrupt.
Co-founder
Josh is an expert in marine robotic perception, navigation, and planning and a recipient of the Office of Naval Research Young Investigator Award. He leads the translation of advanced marine autonomy research into robust systems for real-world underwater operations.
Technology
Aquatonomy's platform combines proprietary software and patented system design. The company's core capabilities span GPS-denied localization, multi-sensor fusion, autonomous control, live 3D mapping, measurement-grade reconstruction, and repeat-inspection intelligence.
More than 17 years of underlying autonomy and mapping research
Technology lineage across CMU, MIT, and the University of Michigan
Field validation with defense, infrastructure, and public-safety organizations
Integrated physical AI and digital AI platform purpose-built for underwater inspection
We welcome conversations with asset owners, engineering and inspection partners, public agencies, research collaborators, and investors.